Product Introduction
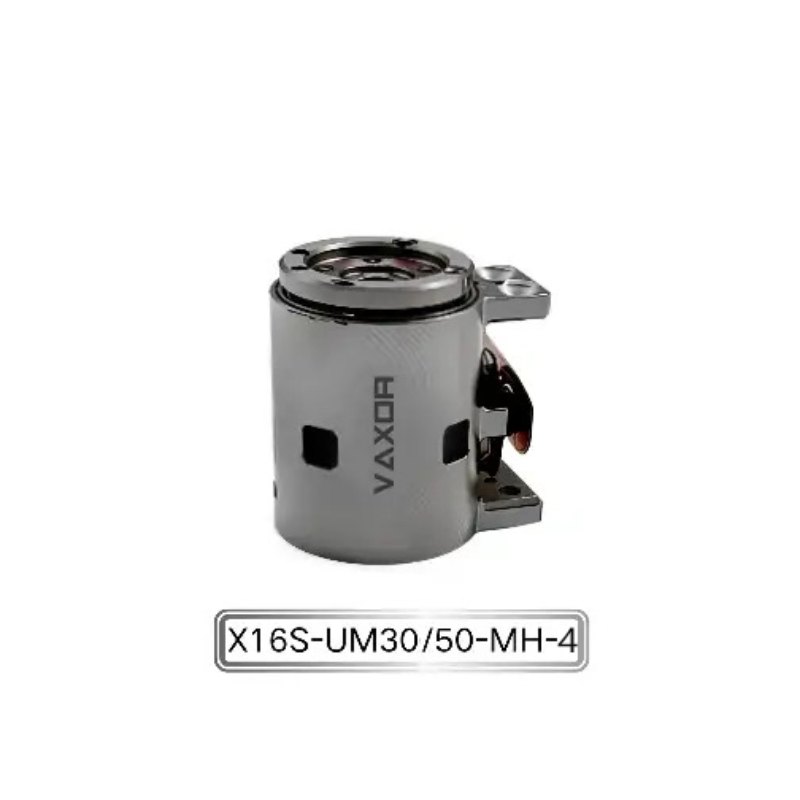
The Φ16mm Micro Joint Actuator is an ultra-compact joint module developed for highly integrated robotic mechanisms, dexterous hands, precision motion systems and other space-constrained applications.
With an outer diameter of only Φ16 mm and a weight of approximately 24.3–26.1 g, the actuator integrates a high-density HDI PCB winding structure, miniature reduction mechanism and absolute magnetic encoder into a compact motion module.
The integrated design is intended to provide high torque density, precise angular control and fast response while reducing the space and weight requirements of robotic joints.
With angular accuracy of up to 0.02°, the actuator is particularly suitable for robotic applications where precise joint positioning and compact mechanical integration are important.
The product is developed by VAXOR, a technology company specializing in micro joint actuators and ultra-micro coreless motors for robotics, medical devices, precision instruments and intelligent equipment.
Key Product Features
1. Ultra-Compact Φ16mm Joint Module
The actuator is designed around a Φ16 mm form factor, making it suitable for robotic mechanisms where conventional joint modules are too large.
Its compact structure allows motion components to be integrated into small robotic joints, end-effectors and highly miniaturized mechanisms.
2. High Torque Density
Despite its miniature size and low weight, the actuator provides:
-
Continuous torque up to 200 mNm
-
Initial torque up to 400 mNm
This torque output is designed for compact robotic joints that require useful mechanical force within a limited installation space.
3. HDI PCB Winding Technology
The actuator uses high-density HDI PCB winding technology to support a compact motor structure.
This approach integrates the winding architecture into the miniature motor design, helping reduce space requirements and supporting high-density integration.
4. High-Precision Absolute Encoder
An absolute magnetic encoder is integrated into the joint actuator.
The encoder provides angular position feedback through SPI communication and supports precise motion control in applications requiring accurate joint positioning.
5. Angular Accuracy up to 0.02°
The actuator can achieve angular accuracy of up to 0.02°.
This high positioning accuracy makes the module suitable for applications such as dexterous robotic hands and highly integrated robotic joints where fine motion control is required.
6. Multiple Gear Ratio Options
The product is available with 30:1 and 50:1 gear ratio configurations.
Different reduction ratios allow designers to balance torque output, speed and mechanical requirements according to the robotic joint application.
7. Low Weight
The module weighs approximately 24.3–26.1 g.
The low weight helps reduce the mechanical load of robotic structures and is particularly relevant to multi-joint robots, robotic hands and compact moving mechanisms.
8. 12V / 24V Voltage Options
The actuator supports 12V and 24V configurations, providing flexibility for different robotic power architectures and system designs.
The final voltage configuration should be selected according to the motor model and system requirements.
Technical Specifications
| Item | Specification |
|---|---|
| Product | Φ16mm Micro Joint Actuator |
| Model | X16S/L-UM30/50-MH-4 |
| Diameter | Φ16 mm |
| Voltage | 12V / 24V |
| Gear Ratio | 30 / 50 |
| Continuous Torque | Up to 200 mNm |
| Initial Torque | Up to 400 mNm |
| Encoder | Absolute Magnetic Encoder |
| Communication | SPI |
| Angular Accuracy | Up to 0.02° |
| Weight | 24.3–26.1 g |
| Motor Structure | HDI PCB Winding |
| Application Focus | Robotics, Dexterous Hands, Compact Motion Systems |
Specifications may vary according to the selected model and configuration.
Compact Joint Architecture
The Φ16mm Micro Joint Actuator integrates the core components required for miniature joint motion into a compact module.
The integrated architecture combines:
-
Micro motor
-
HDI PCB winding
-
Miniature reduction mechanism
-
Absolute magnetic encoder
-
Position feedback
-
SPI communication
This integrated approach reduces the need for designers to independently arrange multiple motion components inside a small joint structure.
It can therefore be considered for robotic mechanisms where installation space, joint weight and positioning accuracy are important design parameters.
Precision Motion Control
The actuator's absolute magnetic encoder provides position feedback for closed-loop motion control.
Through SPI communication, the encoder can interface with a compatible control system for joint position monitoring and control.
The specified angular accuracy of up to 0.02° enables fine positioning for applications requiring controlled and repeatable joint movement.
Actual system-level positioning performance can depend on the controller, mechanical structure, transmission components, assembly accuracy and operating conditions.
Gear Ratio Options
Two gear ratio options are available:
30:1 Gear Ratio
The 30:1 configuration can be considered when the application requires a balance between torque multiplication and joint movement characteristics.
50:1 Gear Ratio
The 50:1 configuration provides a higher reduction ratio and can be selected for applications where greater torque multiplication is required within the joint mechanism.
The appropriate ratio should be selected according to required output torque, motion speed, mechanical load and control requirements.
Torque Capability
The actuator provides a continuous torque of up to 200 mNm and an initial torque of up to 400 mNm.
These values make the module suitable for compact motion applications where a small actuator needs to generate useful joint torque.
For system design, customers should evaluate the required duty cycle, load, operating conditions and control strategy together with the selected actuator configuration.
Applications
The ultra-compact form factor makes the actuator suitable for a variety of miniature motion applications.
Robotic Hands
The actuator is designed for dexterous hands and other robotic end-effectors where multiple compact joints must be integrated into a limited mechanical envelope.
Its small diameter, low weight and precise position feedback support applications involving fine finger or joint movements.
Humanoid and Compact Robots
Multiple micro joint actuators can be considered for highly integrated robotic structures where conventional joint motors may occupy excessive space.
Potential applications include compact robotic limbs, articulated mechanisms and other miniature robotic joints.
Precision Robotic Mechanisms
The actuator can be used in robotic mechanisms requiring precise angular positioning and compact mechanical integration.
The absolute encoder provides position feedback for compatible motion control architectures.
Intelligent Equipment
The module can also be evaluated for intelligent equipment and compact automated mechanisms requiring small, lightweight and controllable motion components.
Medical Devices
VAXOR develops micro-drive products for medical device applications. The Φ16mm actuator can be considered for suitable medical equipment mechanisms where compact motion and precise control are required, subject to application-specific validation.
Typical Application Requirements
The actuator is particularly relevant when a project has several of the following requirements:
-
Extremely limited installation space
-
Low joint weight
-
High torque density
-
Precise angular positioning
-
Integrated position feedback
-
Compact electronic architecture
-
Multiple articulated joints
-
Robotic hand integration
-
Miniature robotic mechanisms
-
High mechanical integration
Model Information
The listed model is:
X16S/L-UM30/50-MH-4
The model family supports 30 and 50 gear ratio configurations and 12V or 24V voltage options.
Before ordering, customers should confirm the required voltage, gear ratio, mechanical interface and control architecture to ensure the selected configuration matches the target robotic system.
Integration Considerations
When integrating the actuator into a robotic mechanism, engineers should consider:
-
Available installation diameter
-
Required continuous torque
-
Required initial torque
-
Gear ratio
-
Operating voltage
-
Required angular accuracy
-
Encoder communication
-
Controller compatibility
-
Mechanical load
-
Joint duty cycle
-
Overall joint weight
-
Installation and structural constraints
The actuator's compact architecture allows designers to focus on the complete joint structure rather than separately packaging the motor, reduction mechanism and position encoder.
Micro Drive Technology
VAXOR develops its micro-drive technology around three key requirements: compact size, high performance and scalable production.
The company's technical approach combines:
-
Axial-flux motor technology
-
HDI PCB/FPCB winding
-
Optimized electromagnetic design
-
Miniature reduction mechanisms
-
Precision manufacturing
-
Robotics control technology
-
Intelligent manufacturing
These technologies are integrated to develop compact motion solutions for robotics, precision instruments, medical devices and intelligent equipment.
R&D and Engineering Capability
VAXOR was founded in 2024 and is headquartered in Suzhou, China.
The company brings together a multidisciplinary engineering team with experience in:
-
Motor design
-
Precision manufacturing
-
Structural design
-
Robotics control
-
Intelligent manufacturing
-
Micro-drive systems
The team focuses on taking high-performance micro motor technologies from prototype validation and engineering development toward scalable production.
Its engineering capability covers prototype validation, pilot production and batch delivery.
Product Development Focus
VAXOR's product development focuses on micro-drive requirements where conventional motor solutions may not provide sufficient integration density.
The company develops micro joint actuators and ultra-micro coreless motors for:
-
Robotics
-
Medical devices
-
Precision instruments
-
Intelligent equipment
-
Compact motion systems
The technology roadmap emphasizes compact dimensions, high power density, precise control, fast response and production consistency.
B2B Selection Guide
Before requesting a quotation for the Φ16mm Micro Joint Actuator, buyers should provide information about:
-
Target robotic application
-
Required joint diameter
-
Continuous torque
-
Peak or initial torque
-
Desired gear ratio
-
Operating voltage
-
Encoder requirements
-
Communication interface
-
Required positioning accuracy
-
Available installation space
-
Expected production quantity
For robotic hand or multi-joint applications, providing the joint structure and motion requirements can help determine the appropriate configuration.
FAQ
What is the diameter of this joint actuator?
The actuator uses a Φ16 mm compact form factor.
What is the maximum continuous torque?
The specified continuous torque is up to 200 mNm.
What is the initial torque?
The specified initial torque is up to 400 mNm.
What gear ratios are available?
The listed configurations include 30 and 50 gear ratios.
What encoder does the actuator use?
It uses an absolute magnetic encoder.
What communication interface is supported?
The encoder communication interface is SPI.
How accurate is the angular positioning?
The specified angular accuracy can reach up to 0.02°.
How much does the actuator weigh?
The listed weight range is approximately 24.3–26.1 g, depending on configuration.
What operating voltage is available?
The product is available in 12V and 24V configurations.
Is it suitable for robotic hands?
Yes. The actuator is specifically designed for applications such as dexterous hands and highly integrated robotic systems.
Can it be used in other compact robotic mechanisms?
Yes. It can be evaluated for compact robotic joints, articulated mechanisms, intelligent equipment and other miniature motion applications according to system requirements.
Does VAXOR support engineering and mass production?
VAXOR's engineering capability covers prototype validation, pilot production and batch delivery, supporting the development of micro-drive products toward scalable production.
Product Summary
The Φ16mm Micro Joint Actuator combines an ultra-compact Φ16 mm form factor, HDI PCB winding, absolute magnetic encoder, 30/50 gear ratios, up to 200 mNm continuous torque and up to 0.02° angular accuracy for highly integrated robotic motion applications.
Reviews
There are no reviews yet.